PhD student Elad Siman Tov spent a month in Canada presenting his research on intersegmental coordination (ISC) and powered prosthesis control at two international conferences.
For 30 years, the Law of Intersegmental Coordination has been reported across subjects and gaits. It describes how the elevation angles of the thigh, shank, and foot covary on a plane. Elevation angles are measured from the vertical, unlike joint angles. The law has been linked to the energetics of walking and the neural control of movement, yet it has rarely been analyzed in amputee gait or used to control prostheses. Elad’s work aims to change that.
World Congress of Biomechanics (WCB 2026), Vancouver, July 11–15, 2026
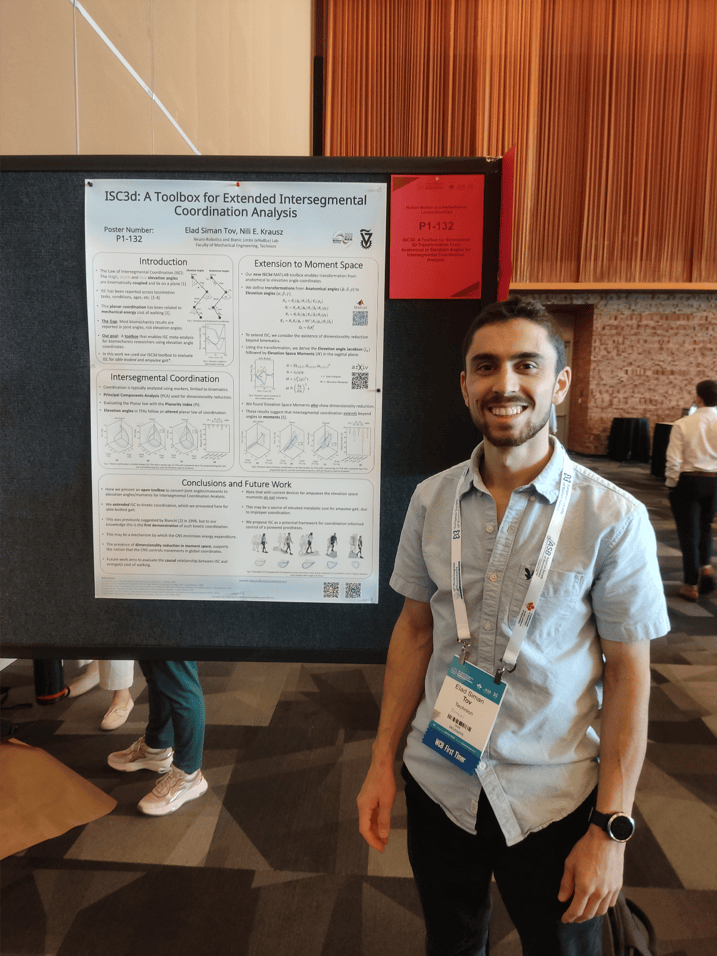
Elad presented a poster on ISC3d, a MATLAB toolbox the lab developed. It converts standard 3D anatomical joint angles directly into elevation angles, so ISC analysis no longer has to start from raw marker data. This makes ISC analysis possible for any standard biomechanics dataset, including previously published ones. The toolbox is freely available on MATLAB Central. Elad also competed in the Three Minute Thesis (3MT) competition, presenting his doctoral research on turning ISC from an observed law of human gait into a control approach for powered prostheses.
IEEE BioRob 2026, Edmonton, August 1–4, 2026
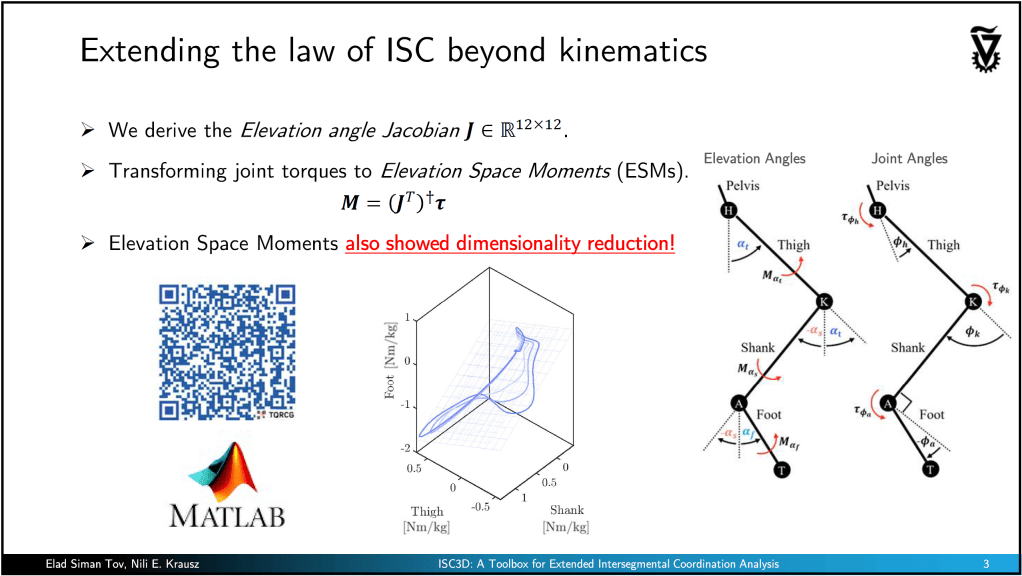
Elad gave an oral presentation on the paper, “Extending the Law of Intersegmental Coordination: Implications for Powered Prosthetic Controls” (E. Siman Tov and N. E. Krausz). The paper extends ISC beyond kinematics to kinetics. It uses a 3D Jacobian to map joint torques into segment elevation angle coordinates, which reveals Elevation Space Moments (ESM). The results show moment-based coordination in able-bodied gait that is absent in amputee gait. The paper also proposes how this extended law of ISC can be applied directly to powered prosthesis control.
He also presented at two workshops:
- Bridging Human Locomotion Neuromechanics and Assistive Robotics: presented the ISC3d toolbox and its extension to elevation space moments, and received the Best Spotlight Talk Award.
- Advanced Human-Machine Interfaces and Control Strategies for Next Generation Wearable Robots: presented “Toward Biomimetic Powered Prosthetic Control via an Extended Law of Intersegmental Coordination.”
Related publications
E. Siman Tov, ISC3d, MATLAB Central File Exchange, Jan. 2026. [Online]. Available: https://www.mathworks.com/matlabcentral/fileexchange/182726-isc3d
E. Siman Tov and N. E. Krausz, “Extending the Law of Intersegmental Coordination: Implications for Powered Prosthetic Controls,” in 2026 11th IEEE RAS/EMBS International Conference on Biomedical Robotics and Biomechatronics (BioRob), Aug. 2026, pp. 428–435. doi: 10.1109/BioRob66782.2026.11680996


Leave a comment